|
Abdelrhman Werby I'm a PhD student at the Institute for Artificial Intelligence, University of Stuttgart, where I'm advised by Kai O. Arras in the Socially Intelligent Robotics group. I'm also a member of the International Max Planck Research School for Intelligent Systems (IMPRS-IS). Before that, during my master's at the University of Freiburg, I worked with Abhinav Valada and Wolfram Burgard on 3D scene graphs for language-grounded navigation and on articulated object estimation. |
|
ResearchI'm interested in robot perception and 3D scene understanding. My work focuses on building structured, open-vocabulary representations of the world, such as 3D scene graphs, and on estimating how articulated objects like doors, drawers, and cabinets move, so that robots can navigate and interact in everyday environments. |
|
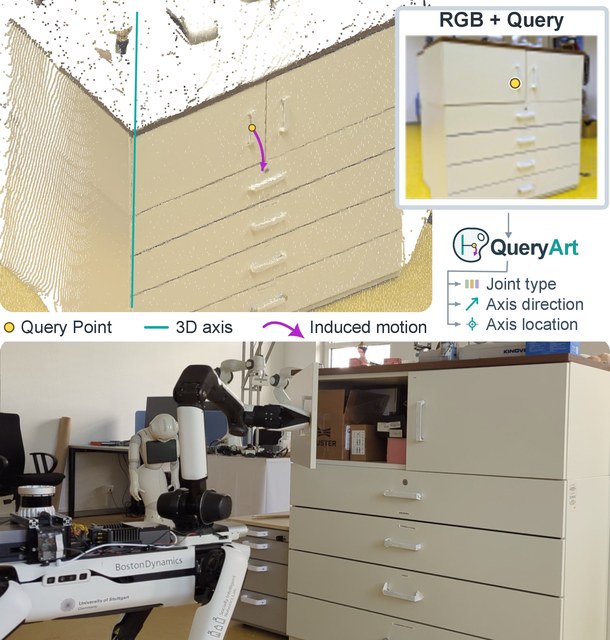
Query-Conditioned Articulation Estimation from a Single Image
Abdelrhman Werby, Fabio Scaparro, Kai O. Arras arXiv, 2026 project page / arXiv / code QueryArt estimates the articulation parameters of an object part from a single RGB image and a 2D query point, then recovers metric scale from one depth measurement. On a mobile manipulator it succeeds in 70.2% of 57 real-world manipulation trials. |
|
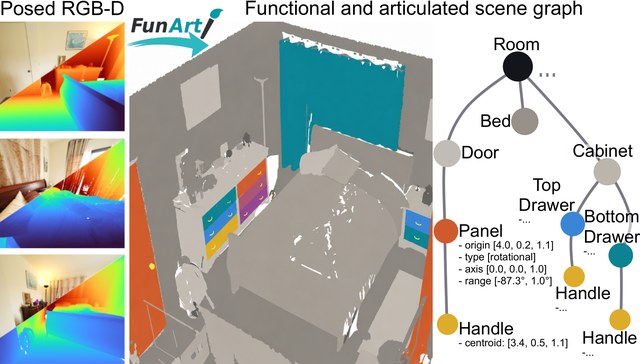
FunArt: Decoding Functional Structure and Articulation from Generative 3D Latents
Dennis Rotondi, Abdelrhman Werby, Kai O. Arras arXiv, 2026 arXiv Decoding functional parts and articulation from the latents of a generative 3D model, giving structural cues that can initialize robotic perception and planning. |
|
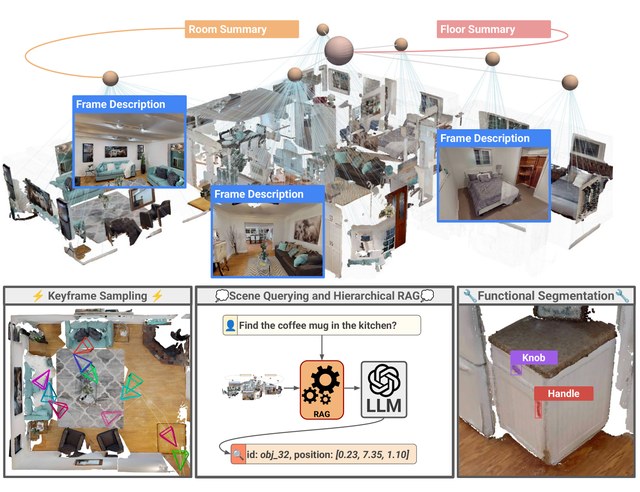
KeySG: Hierarchical Keyframe-Based 3D Scene Graphs
Abdelrhman Werby, Dennis Rotondi, Fabio Scaparro, Kai O. Arras ICRA, 2026 project page / arXiv / code Hierarchical 3D scene graphs built around keyframes, so the scene can be described and queried at multiple levels of detail. |
|
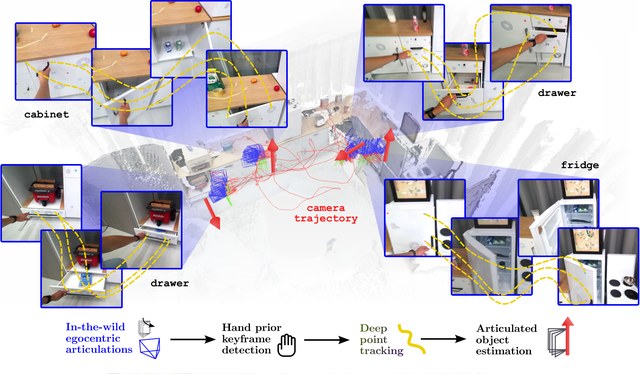
Articulated Object Estimation in the Wild
Abdelrhman Werby*, Martin Büchner*, Adrian Röfer*, Chenguang Huang, Wolfram Burgard, Abhinav Valada * Equal contribution CoRL, 2025 Best Paper Award Runner-Up at the RSS'25 Workshop on Egocentric Perception and Action for Robot Learning project page / arXiv / PMLR ArtiPoint combines deep point tracking with factor graph optimization to estimate articulated parts and their axes from egocentric RGB-D video. We also release Arti4D, the first egocentric in-the-wild dataset of scene-level articulated object interactions. |
|
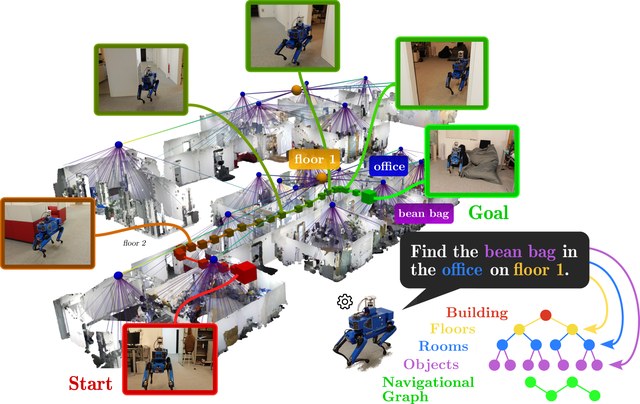
Hierarchical Open-Vocabulary 3D Scene Graphs for Language-Grounded Robot Navigation
Abdelrhman Werby*, Chenguang Huang*, Martin Büchner*, Abhinav Valada, Wolfram Burgard * Equal contribution RSS, 2024 project page / arXiv / code HOV-SG builds a floor / room / object hierarchy of open-vocabulary 3D scene graphs, which lets a robot follow language queries across multi-story buildings. |
Teaching |
| Teaching Assistant, Exercise Mobile Robotics, University of Stuttgart — Winter 2025, Winter 2026 |
|
Website template from Jon Barron. |